Loading...
Searching...
No Matches
FrameStore Class Referencefinal
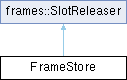
Inheritance diagram for FrameStore:
Public Member Functions | |
| bool | begin () |
| Create the mutex and allocate all slot buffers in PSRAM. False if any allocation fails. | |
| std::optional< size_t > | begin_write () |
| uint8_t * | write_buffer (size_t slot) |
| void | publish (size_t slot, const frames::FrameMeta &meta) |
| void | abort_write (size_t slot, frames::AbortReason reason) |
| std::optional< frames::FrameLease > | acquire_latest () |
| const uint8_t * | data (const frames::FrameLease &lease) const |
| bool | add_subscriber (TaskHandle_t task) |
| Register a task to wake (xTaskNotifyGive) on every publish. | |
| void | remove_subscriber (TaskHandle_t task) |
| Unregister a task. Unknown or null handles are ignored. Remove before deleting the task. | |
| TaskHandle_t | start_subscriber_task (TaskFunction_t entry, const char *name, uint32_t stack_bytes, UBaseType_t priority, BaseType_t core, void *arg) |
Creates a task pinned to core and registers it as a subscriber, so it is woken on every publish. | |
| FrameStoreStats | stats () |
| bool | ready () const |
| True only after a fully successful begin(). Every other call is a safe no-op before that. | |
| void | release_slot (size_t slot) override |
 Public Member Functions inherited from frames::SlotReleaser | |
Static Public Attributes | |
| static constexpr size_t | kSlotBytes = 32 * 1024 |
| static constexpr size_t | kMaxSubscribers = 2 |
| Maximum number of tasks woken on each publish (stream task + detection task). | |
Member Function Documentation
◆ add_subscriber()
| bool FrameStore::add_subscriber | ( | TaskHandle_t | task | ) |
Register a task to wake (xTaskNotifyGive) on every publish.
- Returns
- false when all kMaxSubscribers slots are taken; adding a handle already registered is a no-op that returns true. Safe from any task; no heap.
◆ release_slot()
|
overridevirtual |
Implements frames::SlotReleaser.
◆ start_subscriber_task()
| TaskHandle_t FrameStore::start_subscriber_task | ( | TaskFunction_t | entry, |
| const char * | name, | ||
| uint32_t | stack_bytes, | ||
| UBaseType_t | priority, | ||
| BaseType_t | core, | ||
| void * | arg ) |
Creates a task pinned to core and registers it as a subscriber, so it is woken on every publish.
Shared by the stream and detection tasks. If the subscriber slots are full the new task is deleted again, so the caller never owns a task that is not subscribed.
- Returns
- The task handle, or nullptr if creation or registration failed (already logged).
The documentation for this class was generated from the following files:
- lib/frame_store/include/frame_store.h
- lib/frame_store/src/frame_store.cpp
