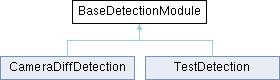
An abstract base class (Interface) that defines the contract for detection algorithms. This class allows the Controller to remain agnostic of the specific detection method (e.g., Color, AI, or Motion) by providing a consistent interface. More...
#include <base_detection_module.h>
Public Member Functions | |
| virtual | ~BaseDetectionModule ()=default |
| Virtual destructor to ensure proper cleanup of derived classes. | |
| virtual std::tuple< MoveX, MoveY > | detect_object (camera_buffer_t frame)=0 |
| Analyzes a camera frame to locate a specific object. | |
| virtual TrackSnapshot | get_track_snapshot () const |
| Latest tracker output, safe to call from another task (implementations copy under a lock). | |
| virtual void | reset () |
| Drop the current target and background. Implementations must make this safe to call from any task. | |
| virtual DetectionStats | get_stats () const |
| Detection timings and counters for the stats line. | |
Detailed Description
An abstract base class (Interface) that defines the contract for detection algorithms. This class allows the Controller to remain agnostic of the specific detection method (e.g., Color, AI, or Motion) by providing a consistent interface.
Member Function Documentation
◆ detect_object()
|
pure virtual |
Analyzes a camera frame to locate a specific object.
- Parameters
-
frame Pointer to the ESP32-CAM frame buffer (camera_fb_t).
- Returns
- std::tuple<uint8_t, uint8_t> Returns a tuple containing:
Implemented in CameraDiffDetection.
◆ get_stats()
|
inlinevirtual |
Detection timings and counters for the stats line.
Reimplemented in CameraDiffDetection.
◆ get_track_snapshot()
|
inlinevirtual |
Latest tracker output, safe to call from another task (implementations copy under a lock).
- Returns
- Default (Idle) snapshot when the module does not track.
Reimplemented in CameraDiffDetection.
◆ reset()
|
inlinevirtual |
Drop the current target and background. Implementations must make this safe to call from any task.
Reimplemented in CameraDiffDetection.
The documentation for this class was generated from the following file:
- lib/detection/include/base_detection_module.h
